Expert manipulation, captured to your spec and graded for policy learning.
We capture contact-rich, deformable work from the experts who do it every day. Three synchronized cameras (head-mounted plus one on each wrist, 4K at 30 fps) are frame-aligned, with hand and finger pose recovered per frame. Every episode is consented, expert-graded and collected to your task specification.
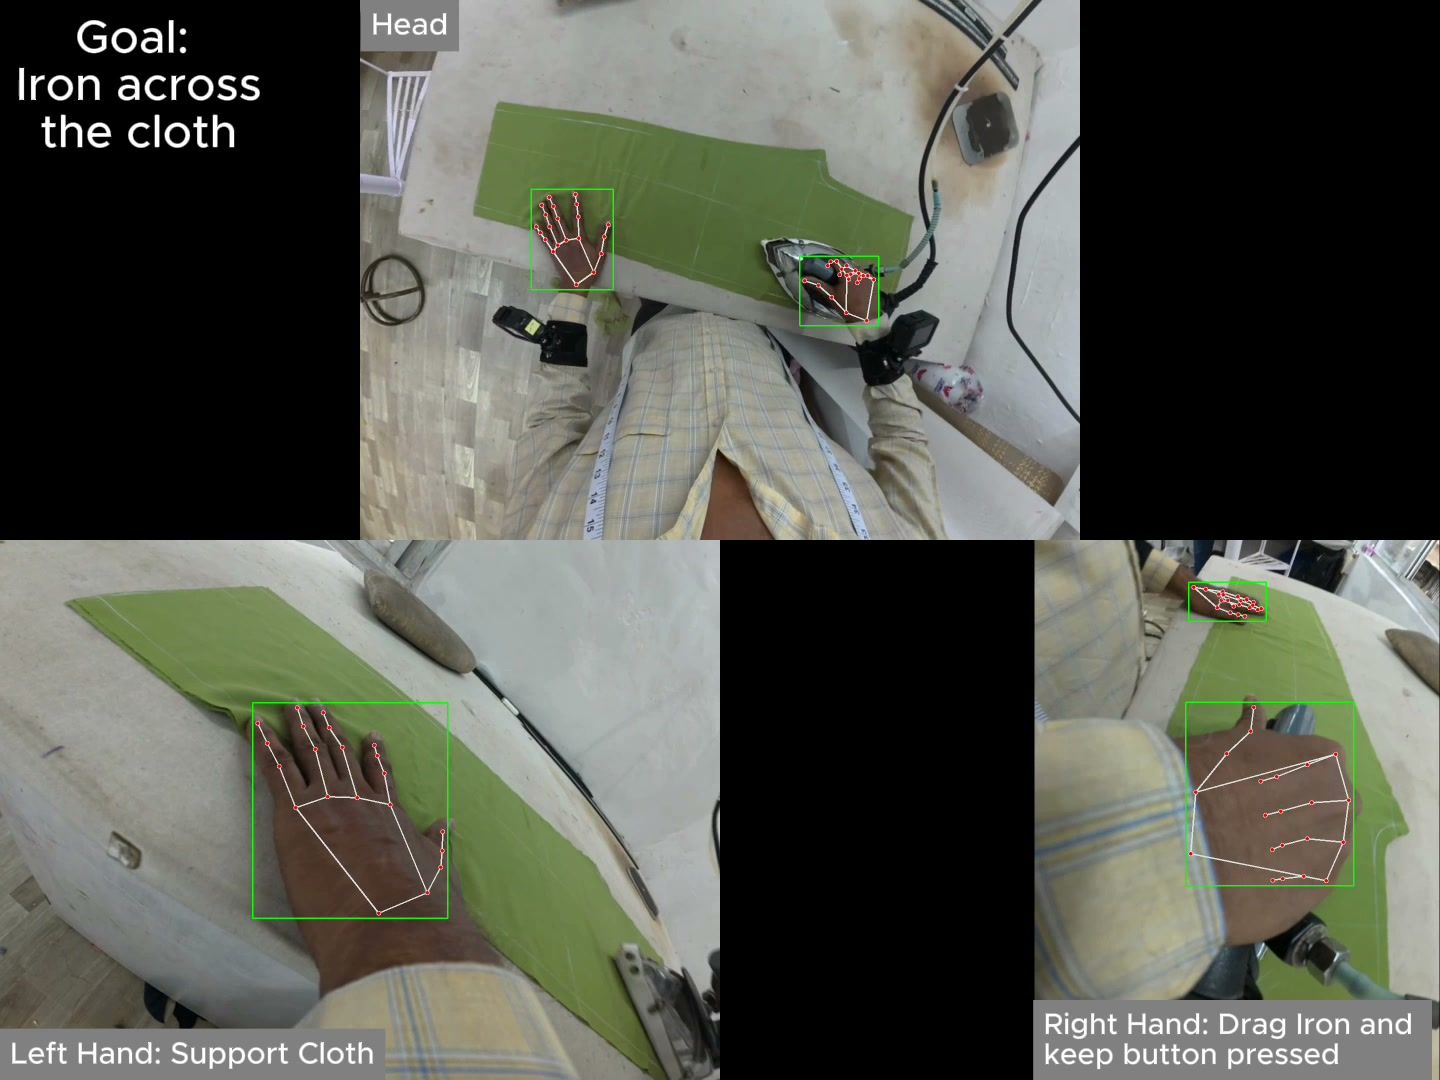
Textile pilot · 2026
An expert garment worker ironing on a working production line. One clip from the textile pilot: about 16 hours of graded sample episodes of the capability.
- Composite
- 3 cameras, 4K @ 30 fps
- Views
- Head + both wrists
- Signal
- Recovered hand pose
Real work, recovered as trainable signal.
Contact-rich, deformable manipulation is where simulation and world models are weakest. We capture it from professionals doing their real jobs, then recover it into trainable signal.
Expert demonstration
Skilled operators perform the tasks you specify, in the settings where they do that work every day. Consent is signed before the first frame is recorded.
Signal recovery & structuring
Hand and finger pose recovered per frame (MediaPipe, 21 keypoints per hand). Sub-task segmentation, action labels and success flags applied against a defined task taxonomy.
Expert grading & packaging
Every episode carries an expert-verified quality grade; only graded data ships. Delivered in LeRobot, RLDS, or raw plus HDF5, with a full datasheet and provenance record.
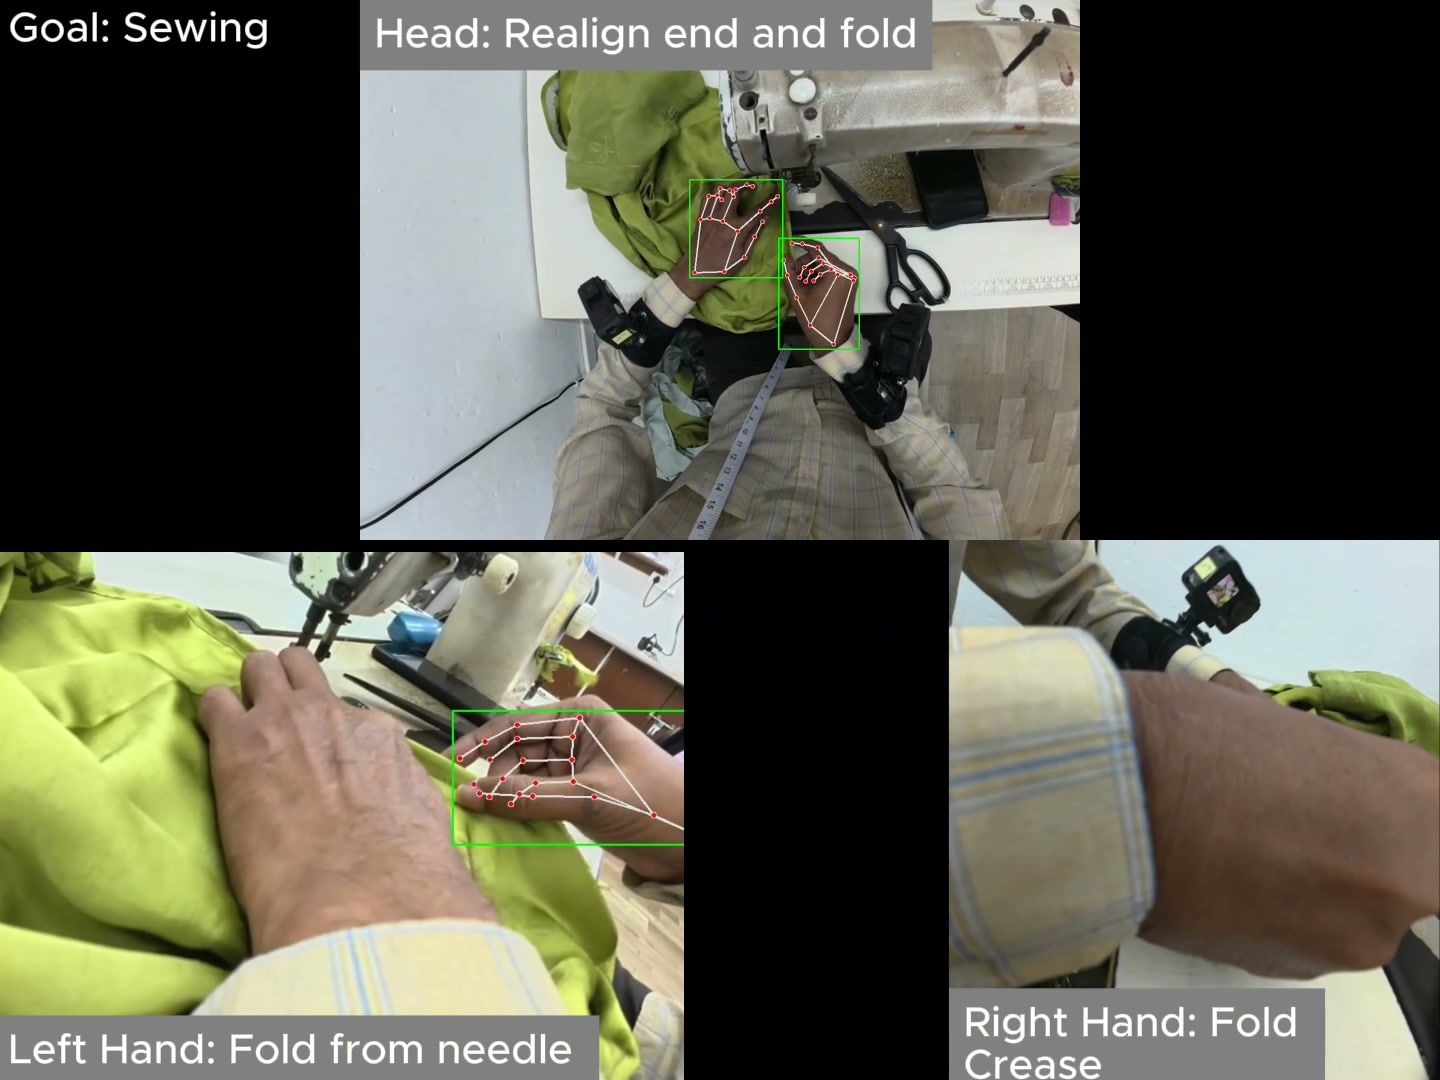
The raw source signal every later layer is recovered from, as an operator sews two fabrics together.
- Stage
- Raw capture
- Views
- Head + both wrists
- Sync
- Frame-aligned
What ships in every episode.
Seven time-aligned layers per demonstration. Train on the ones your policy needs.
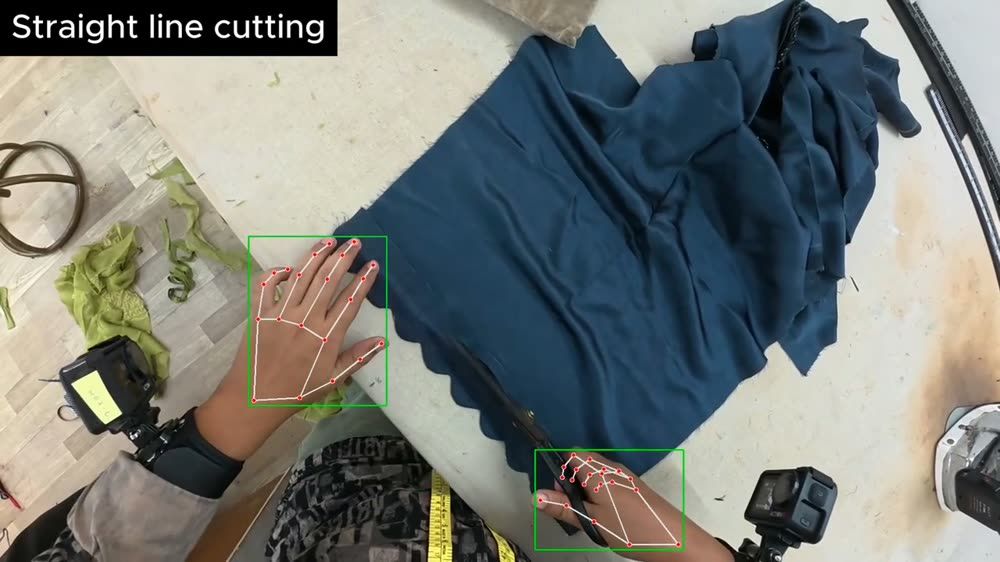
The top two layers made visible: recovered hand keypoints, the action itself, rendered over the egocentric RGB stream as an expert cuts to a line.
- Stream
- Egocentric RGB
- Overlay
- Hand keypoints
- Layer
- The action
Consented at the source. Documented for procurement.
For a policy you'll ship, where the data came from matters as much as what's in it. Every operator consents to the capture and its use, and every episode carries an auditable provenance and licensing trail from the first frame.
Informed, on the record
Operators consent to the capture and its downstream use before recording. Consent scope is tracked per collection.
Auditable provenance
Source, rights, and licensing travel with every episode as metadata, traceable end to end.
Ready for legal review
Every collection ships with a Datasheets for Datasets record: who, where, how and under what licence. Exclusive licences are available.
Garment work is sampled. Six more verticals are captured to spec.
Garment and leather-goods work has graded sample episodes you can load now. Kitchen prep, light assembly, produce packing, moving, jewellery and food manufacturing are captured on request, to your task specification, in structured blocks.
Garment & leather-goods work
Deformable manipulation, sample episodes available
The textile sample: expert garment work, ready to evaluate.
Multi-camera egocentric demonstrations from working garment-industry professionals. Documented to the Datasheets for Datasets standard, packaged so an ML engineer gets value in under ten minutes.
The full set of sample episodes is available on request.
- Domain
- Industrial garment / leather-goods
- Task family
- Deformable, bimanual, contact-rich
- Sample data
- ~16 hours of graded sample episodes
- Captured to date
- 200+ hours, more to spec
- Subjects
- Expert operators, real production
- License
- Commercial; exclusive licences available
Thanks, we've got it.
We reply within one business day with access to the sample episodes.
Have a specific task, view, or embodiment in mind? Reply to that email and we scope it.
From sample to production program.
Sample
Load the textile sample episodes. Inspect the signal, the hand pose and the grading.
Pilot to spec
Tell us the tasks, embodiment, and modalities you need. We collect a scoped block to your specification.
Production program
Scale to a recurring, multi-hundred-hour collection program across any vertical, exclusive if you need it.
Tell us what your policy needs to learn.
We reply within one business day with sample access, then scope the capture your policy needs.
Request sample episodes